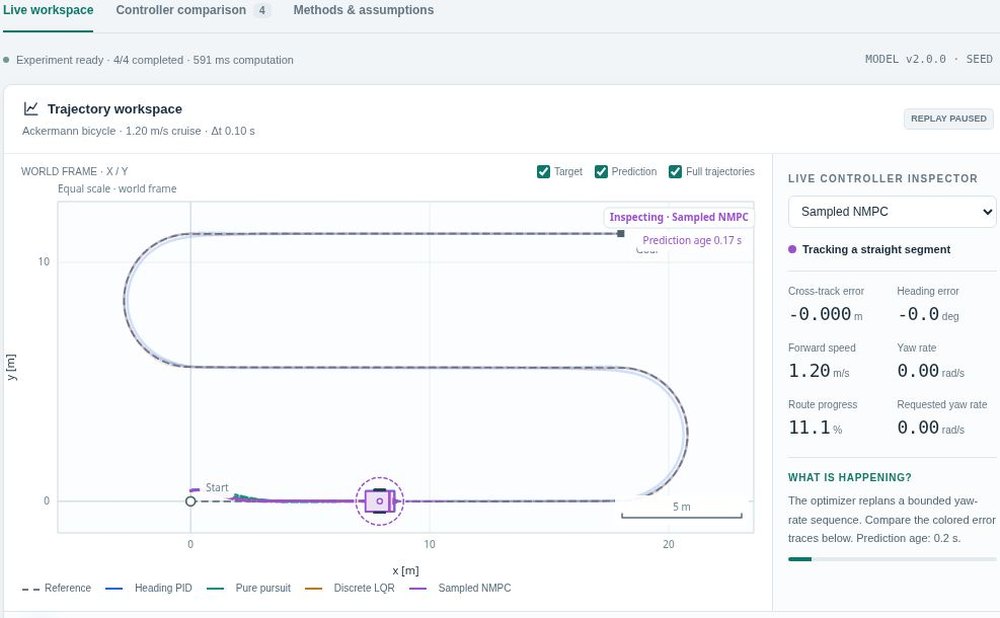
 Demo screenshot
Navigation & control
RobotDSS · Control Lab
Compare heading PID, pure pursuit, discrete LQR and sampled NMPC on the same configurable robot and reference route.
The interactive demo opens in a new tab. Explore its controls and assumptions directly.
Video walkthrough
If the embedded player is unavailable, open the video directly.
Open video ↗