Istituto Italiano di Tecnologia
VINUM / Roberry mobile manipulator
Research mobile manipulator used to investigate grape harvesting and vine pruning.
About this robot
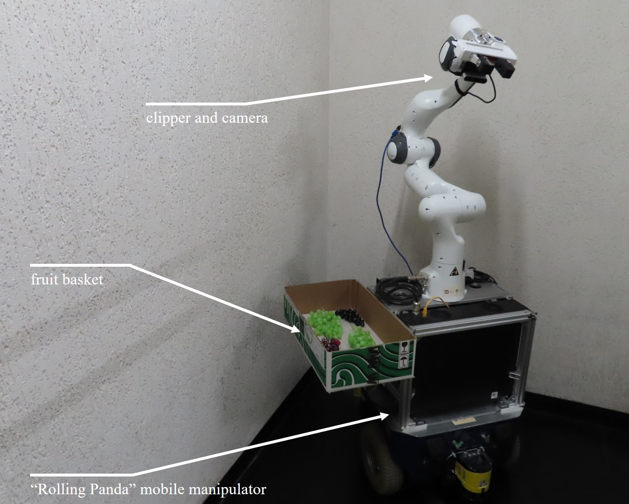
IIT’s VINUM work demonstrated a laboratory mobile manipulator for pruning in 2019 and a table-grape harvesting configuration with a Panda arm and custom clipper. The harvesting tests used artificial grapes and leaves in a mock-up environment. Related pruning and harvesting configurations are kept together because the sources do not establish separate product models.
Product specifications
Detailed specifications have not been added. Refer to the official product page for model-specific information.
Blank specifications mean not recorded. Figures may use different test conditions.