Purdue University
Purdue P-AgBot
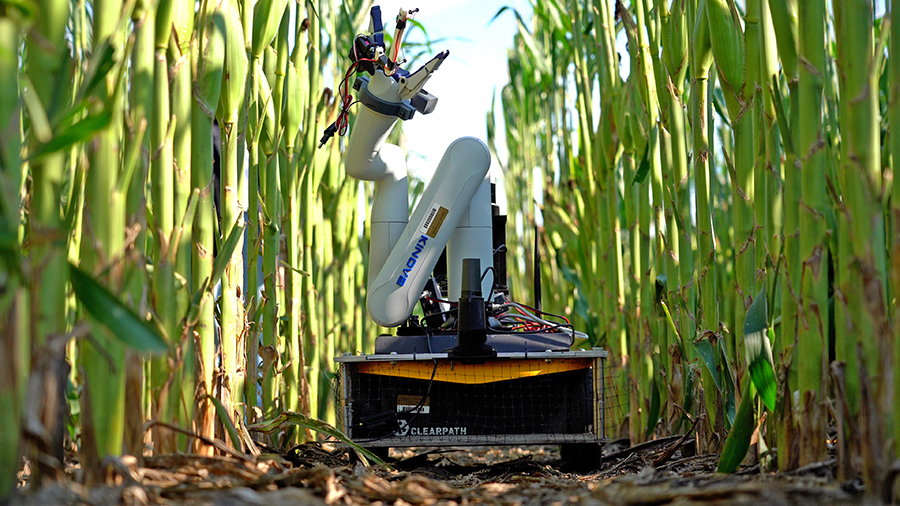
Agricultural research robot for under-canopy navigation, sensing and physical leaf sampling.
About this robot
Purdue described this integrated platform in its 2026 IoT4Ag research update. It combines a Jackal mobile base, a Kinova arm and an agricultural sensor suite. Custom navigation and leaf-grasp planning algorithms support crop monitoring and sampling within narrow rows.
Product specifications
| Manipulator | Kinova Gen3 Lite, six degrees of freedom |
|---|---|
| Research base | Clearpath Jackal |
Blank specifications mean not recorded. Figures may use different test conditions.