Wageningen University & Research
SWEEPER
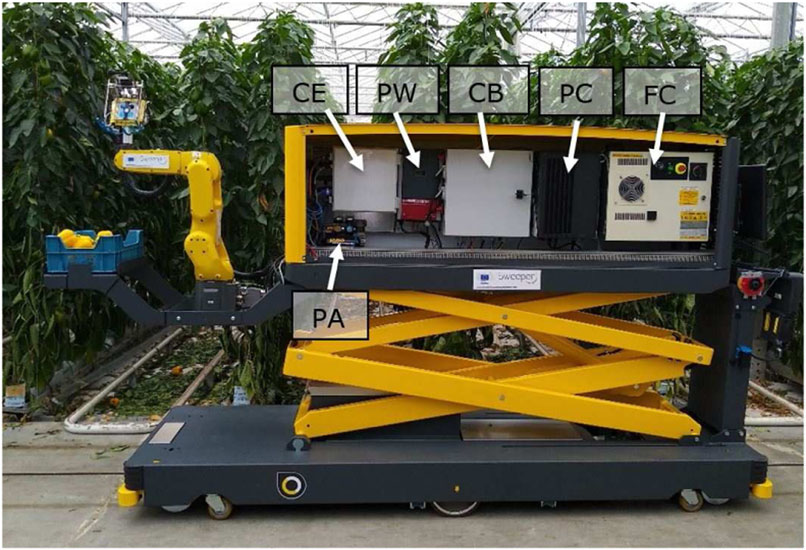
Sweet-pepper harvesting research robot with a vision-guided arm on an autonomous greenhouse cart.
About this robot
Developed by the SWEEPER consortium with Wageningen University & Research, Ben-Gurion University and Umeå University, this prototype locates and harvests greenhouse sweet peppers. A six-axis arm and specialized cutting-and-catching tool operate from a cart that travels on pipe rails and concrete floors. A 2020 paper reports trials on 262 fruits over four weeks in a commercial greenhouse. This is the historical research system from the 2015–2018 project.
Product specifications
| Crop | Sweet pepper |
|---|---|
| Manipulator | 6 degrees of freedom |
| Trial sample | 262 fruits over four weeks |
| Mean trial cycle time | 24 seconds per fruit; experimental conditions, not a commercial guarantee |
Blank specifications mean not recorded. Figures may use different test conditions.