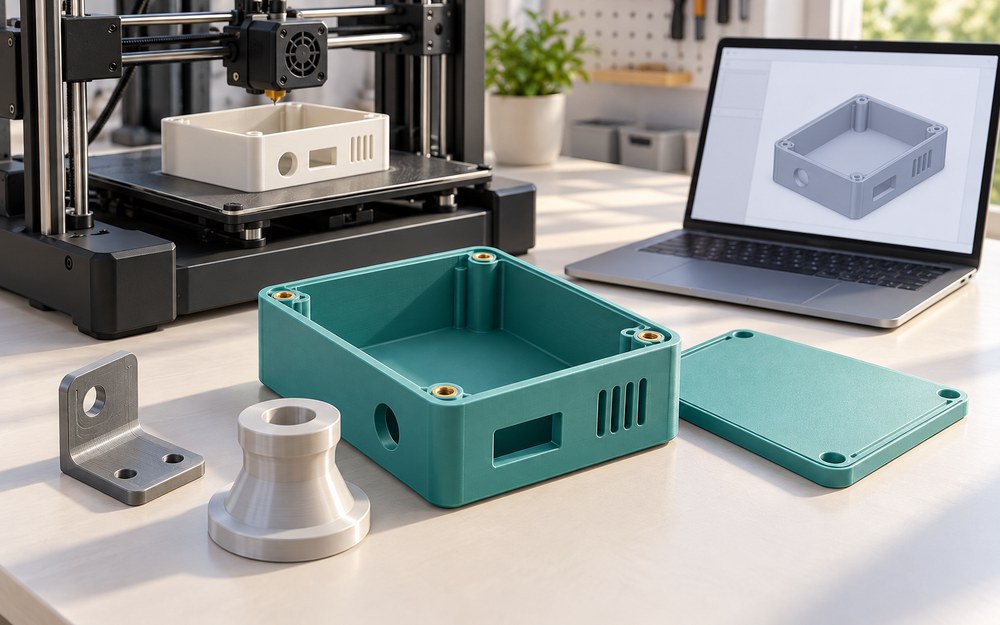
 Design studio
Illustrative preview
Part Studio · Design to Print
Create parametric enclosures, brackets and custom shapes, inspect dimensions, and export meshes for a slicer.
 DEMONSTRATION LAB
Launch a demo, watch it in action,
or explore its technical note.
46 demonstrations to explore
Clear filters ×Design studioCreate parametric enclosures, brackets and custom shapes, inspect dimensions, and export meshes for a slicer.
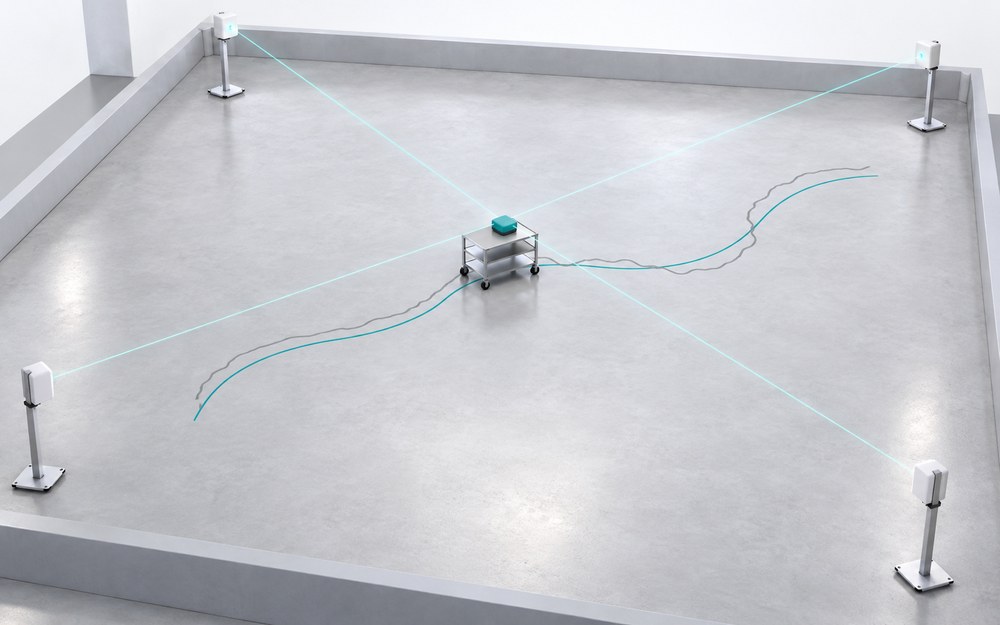 Sensing & automation
Compare noisy UWB range estimates with a reference trajectory and export a scientific localization figure.
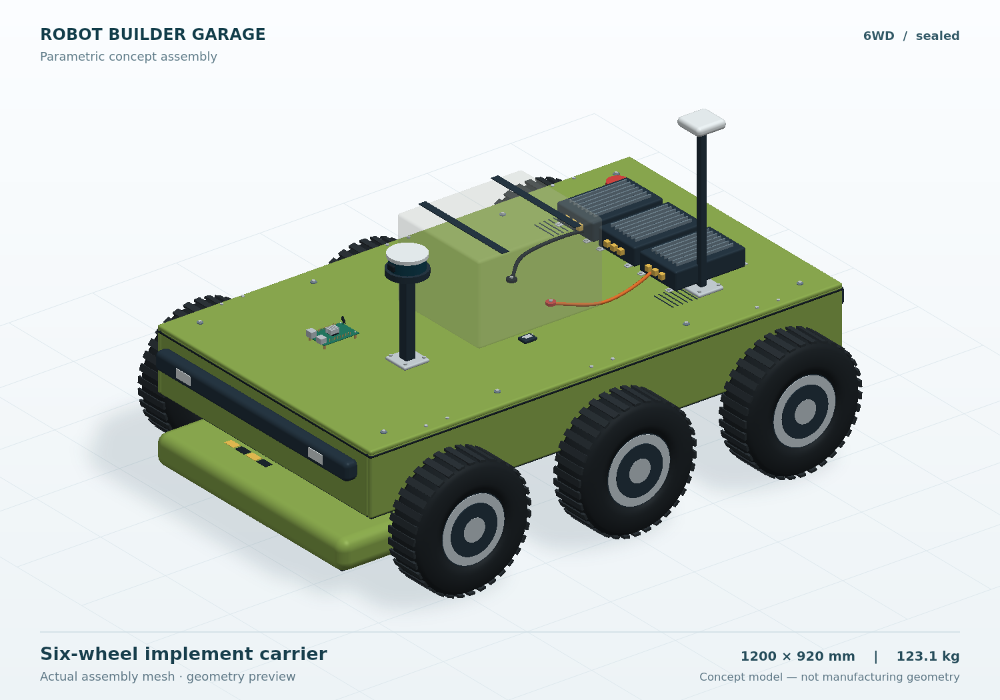 Design studio
Explore the original robot configuration workspace with a live 3D concept, component inspection, engineering checks, parts list, and design comparisons.
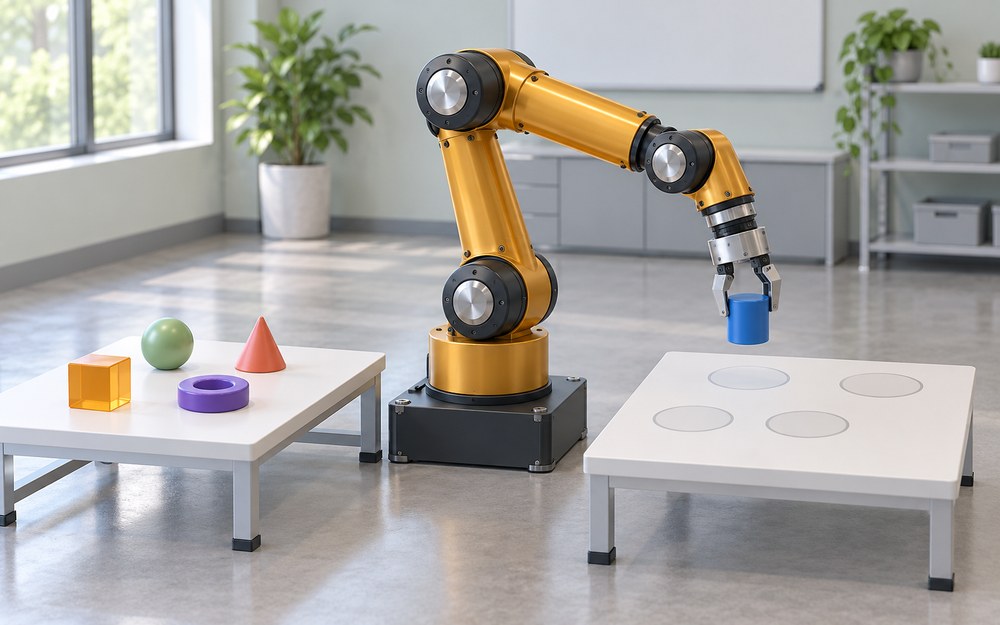 Harvest & manipulation
Explore a six-axis teaching arm, select parts and destinations, and watch a pick-and-place sequence.
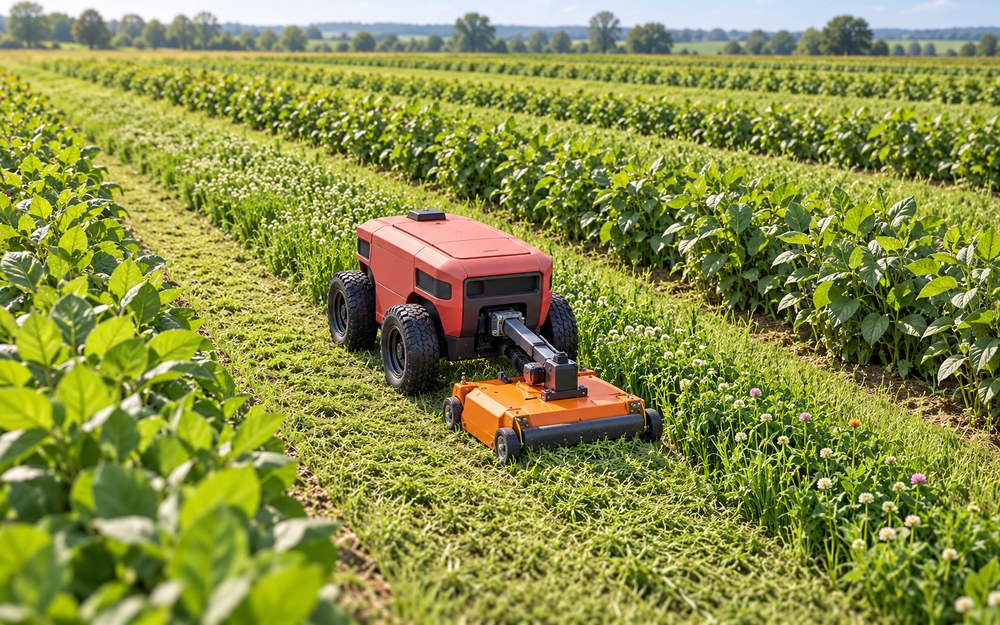 Field robotics
Watch a narrow mowing robot cover row lanes and explore how speed and cutting intensity change the animation.
 Data workspace
A protected workspace for GPS recordings, connected device uploads, and field sessions.
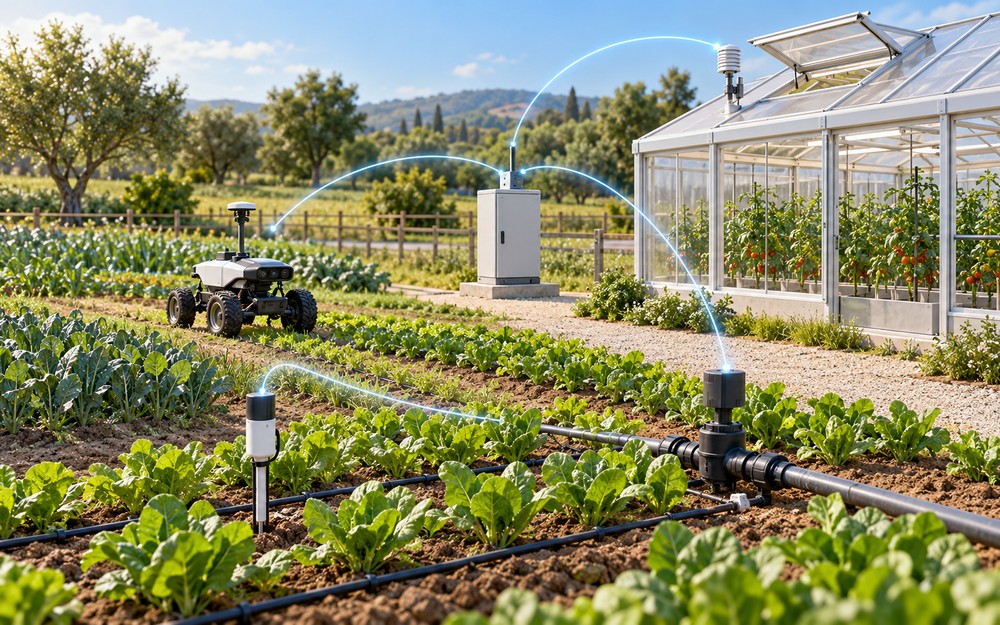 Sensing & automation
Explore the proposed AGRIOS architecture, application areas and roadmap for connecting agricultural sensors, data platforms and robotic systems.
 Collections & people
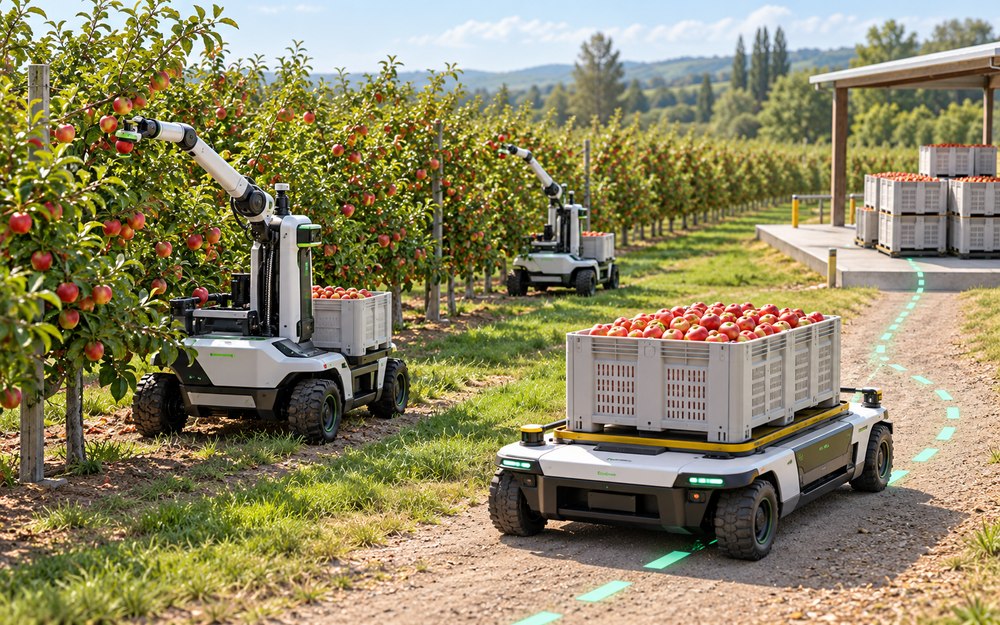
An exhibition entry point for FieldPilot and Harvest Relay, bringing navigation and cooperative harvest logistics together.
 Collections & people
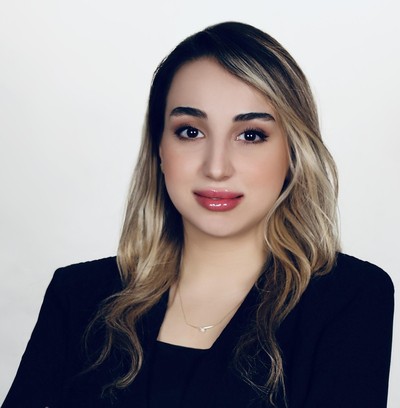
Meet the robotics engineer and explore her work in agricultural mobile robots, mechanical modelling and dynamic simulation.
 Harvest & manipulation
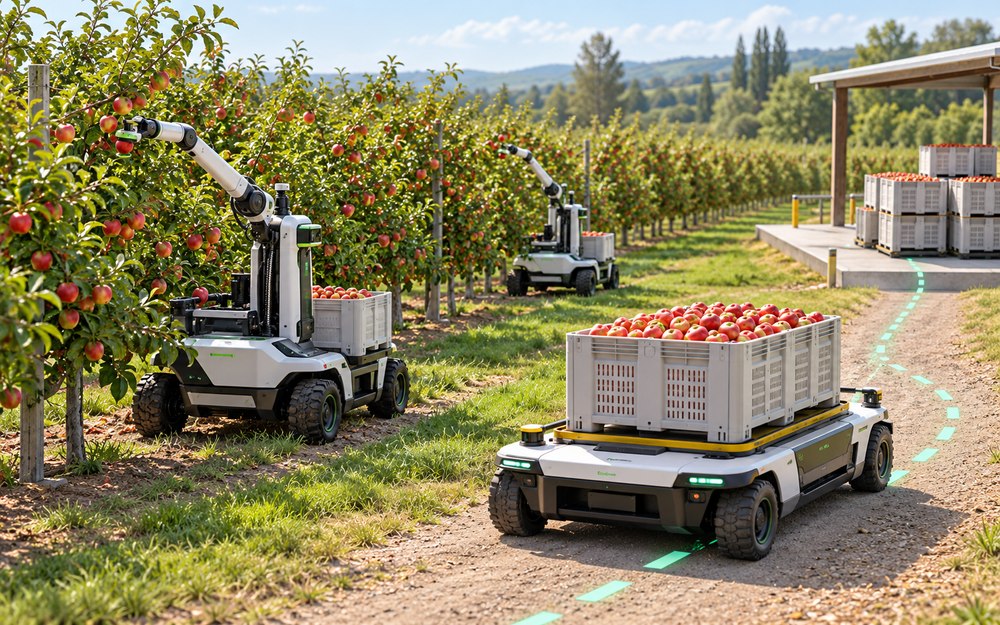
Explore a simulated orchard logistics system, coordinate harvesting and transport robots, and inspect material flow, shared resources and fleet capacity.
Sensing & automationRun an interactive localization experiment with anchor placement, range noise and bias. Compare the prescribed robot route with its estimated position and uncertainty.
 Sensing & automation
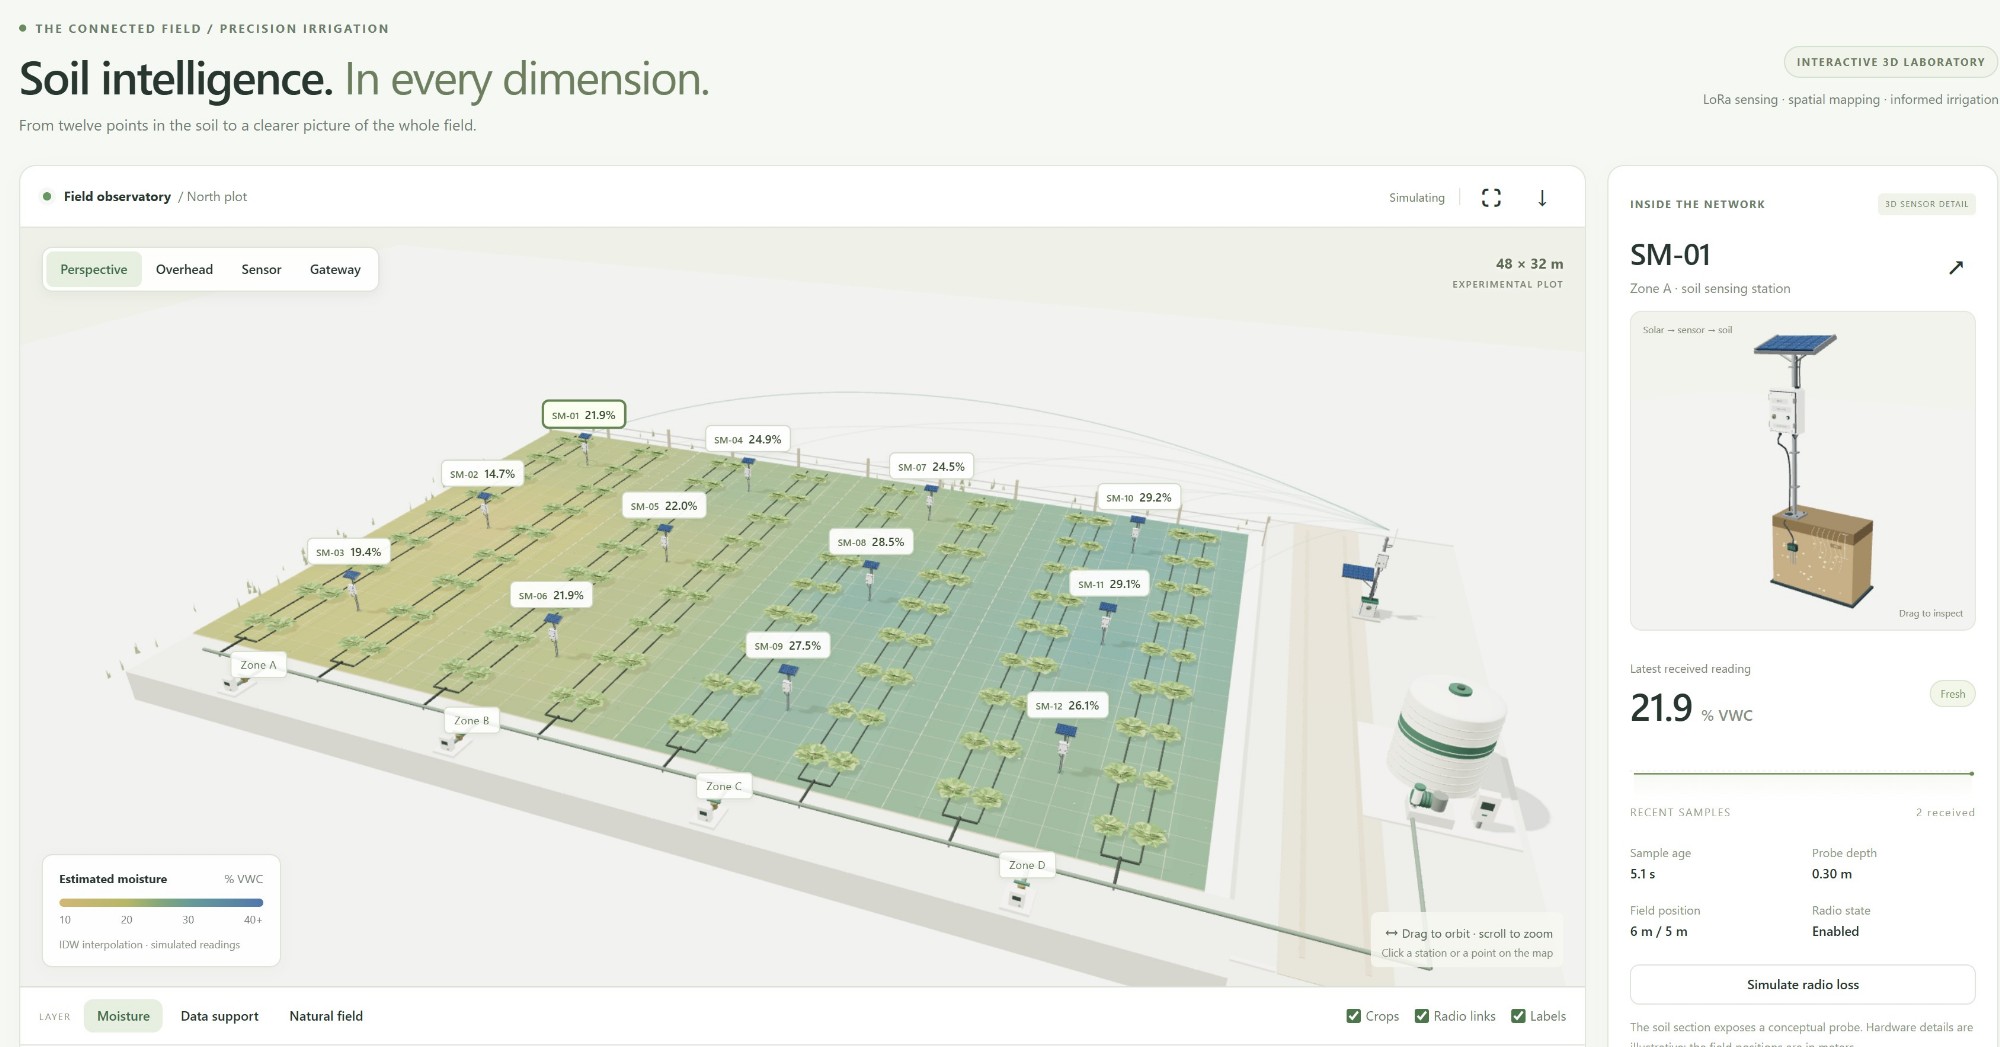
Explore a simulated LoRa soil-moisture network, examine spatial interpolation between sensors, and investigate how the estimated moisture map informs irrigation decisions.